`_
分支和 ``gpt-5.5`` 模型:
From c19727c7bbdd277cd86a985aae3f2741ba01df7a Mon Sep 17 00:00:00 2001
From: ye shengjie <184427520+ye1457@users.noreply.github.com>
Date: Wed, 16 Sep 2026 14:54:10 +0000
Subject: [PATCH 02/13] docs(benchmarks): apply corrected model results and
resource snapshot
---
README.md | 2 +-
README.zh-CN.md | 2 +-
docs/source-en/rst_source/benchmarks.rst | 18 +++++++++---------
docs/source-en/rst_source/overview.rst | 4 ++--
docs/source-zh/rst_source/benchmarks.rst | 18 +++++++++---------
docs/source-zh/rst_source/overview.rst | 4 ++--
6 files changed, 24 insertions(+), 24 deletions(-)
diff --git a/README.md b/README.md
index 6189c87fa..6d8f77efd 100644
--- a/README.md
+++ b/README.md
@@ -33,7 +33,7 @@ Compare RPent with reference methods on LIBERO, LIBERO-PRO, RoboCasa365 Target50
Codex / GPT-6 Astra / low / reasoning: **92.63% Overall (741/800)** across all eight LIBERO-PRO suites. See the [suite results](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html), including the separately frozen Long and Spatial/Object/Goal memory batches.
-[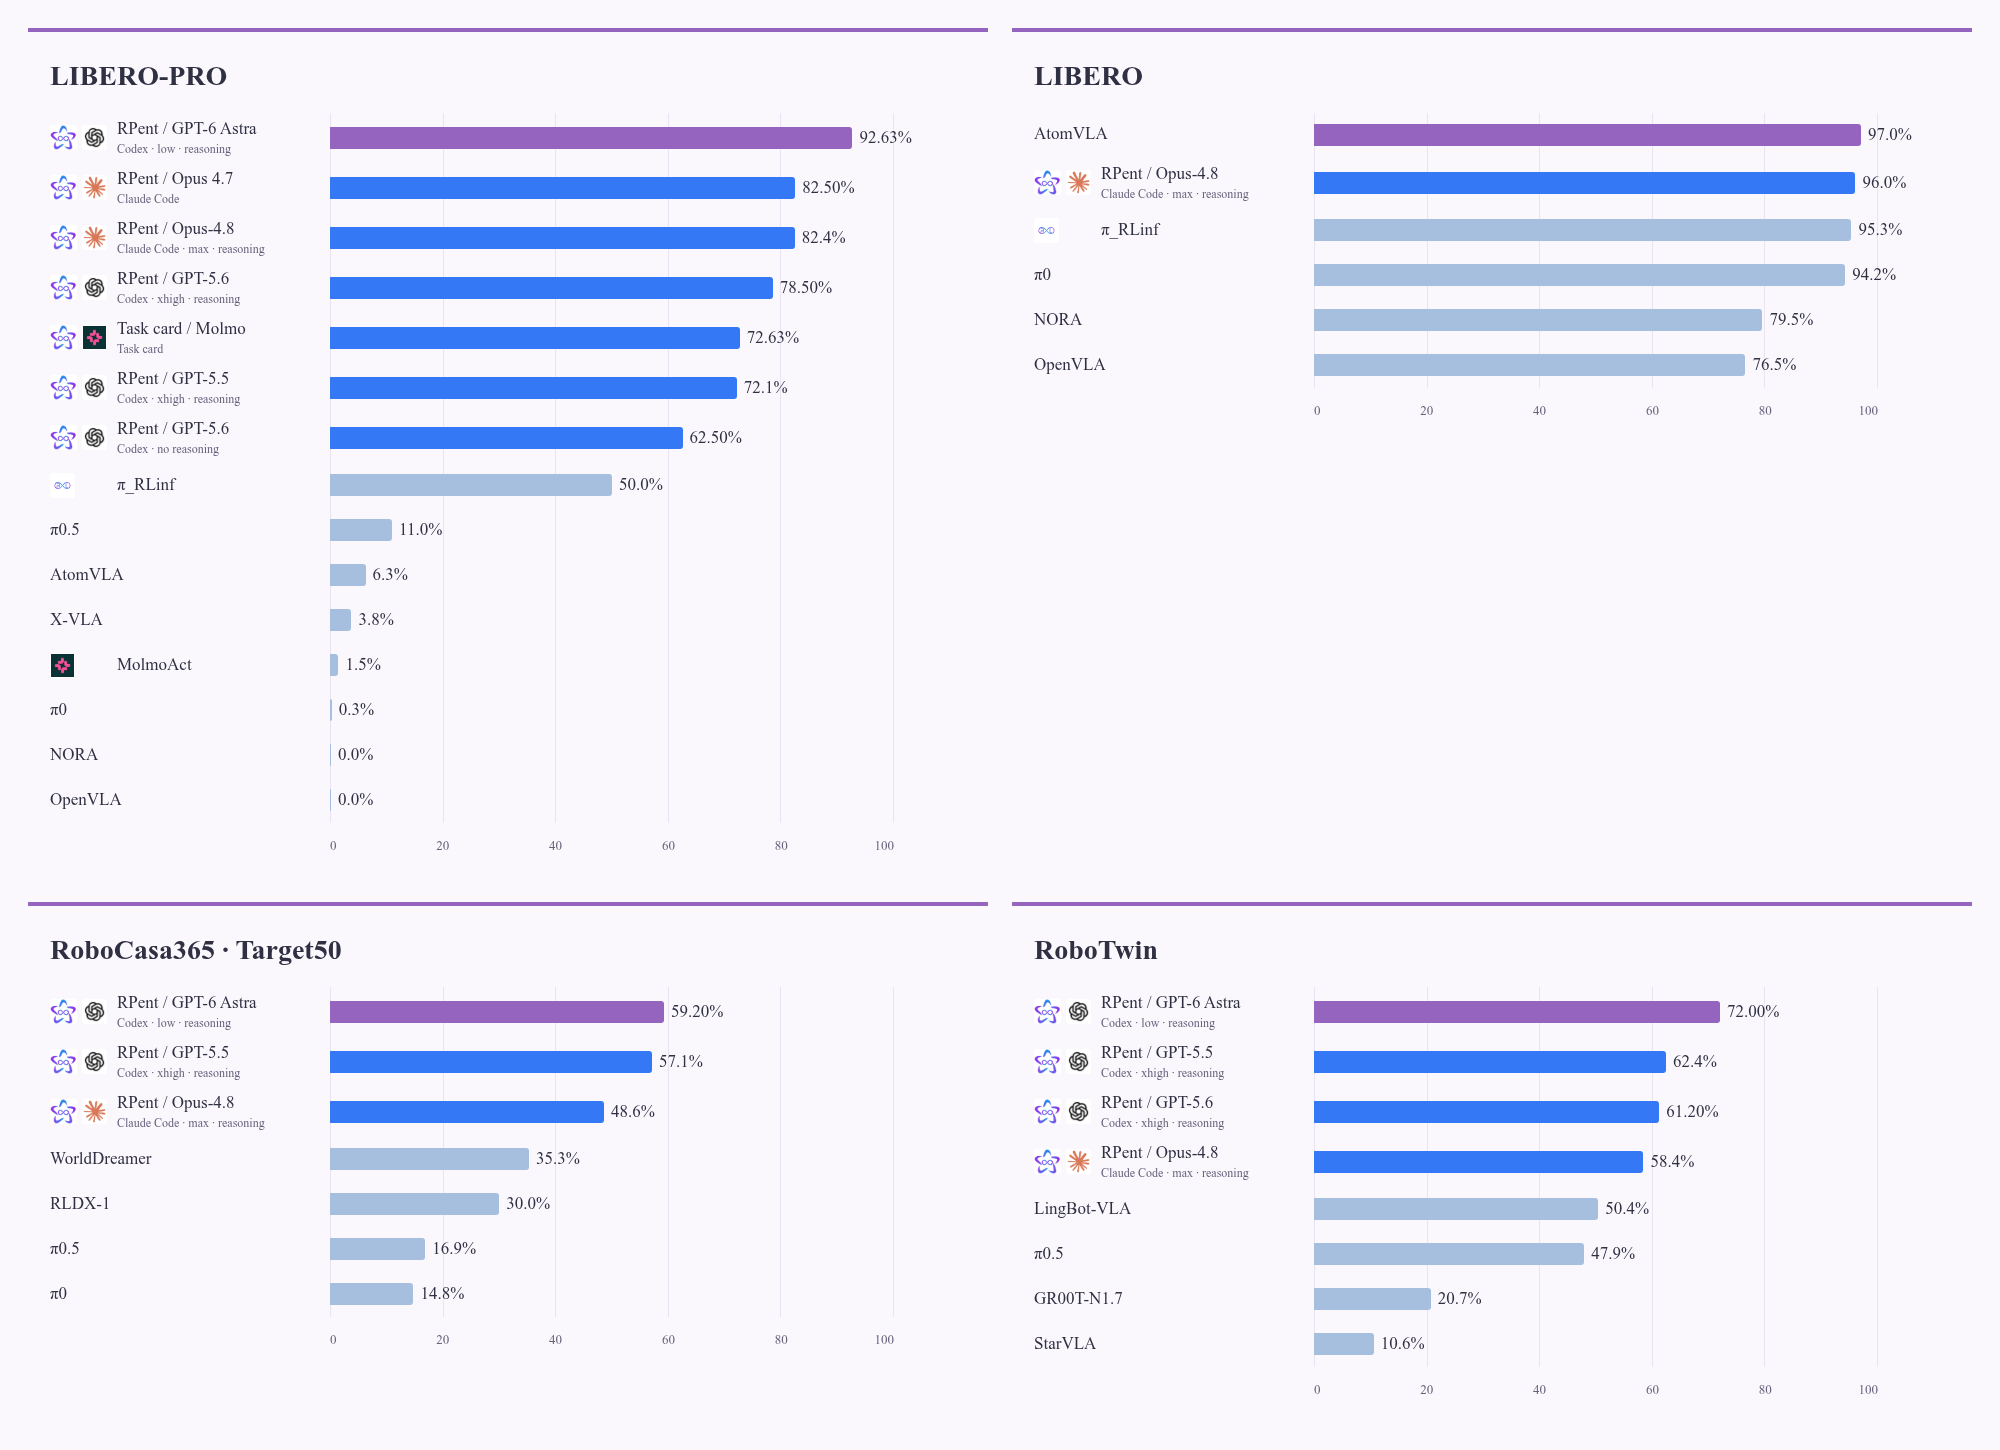](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html)
+[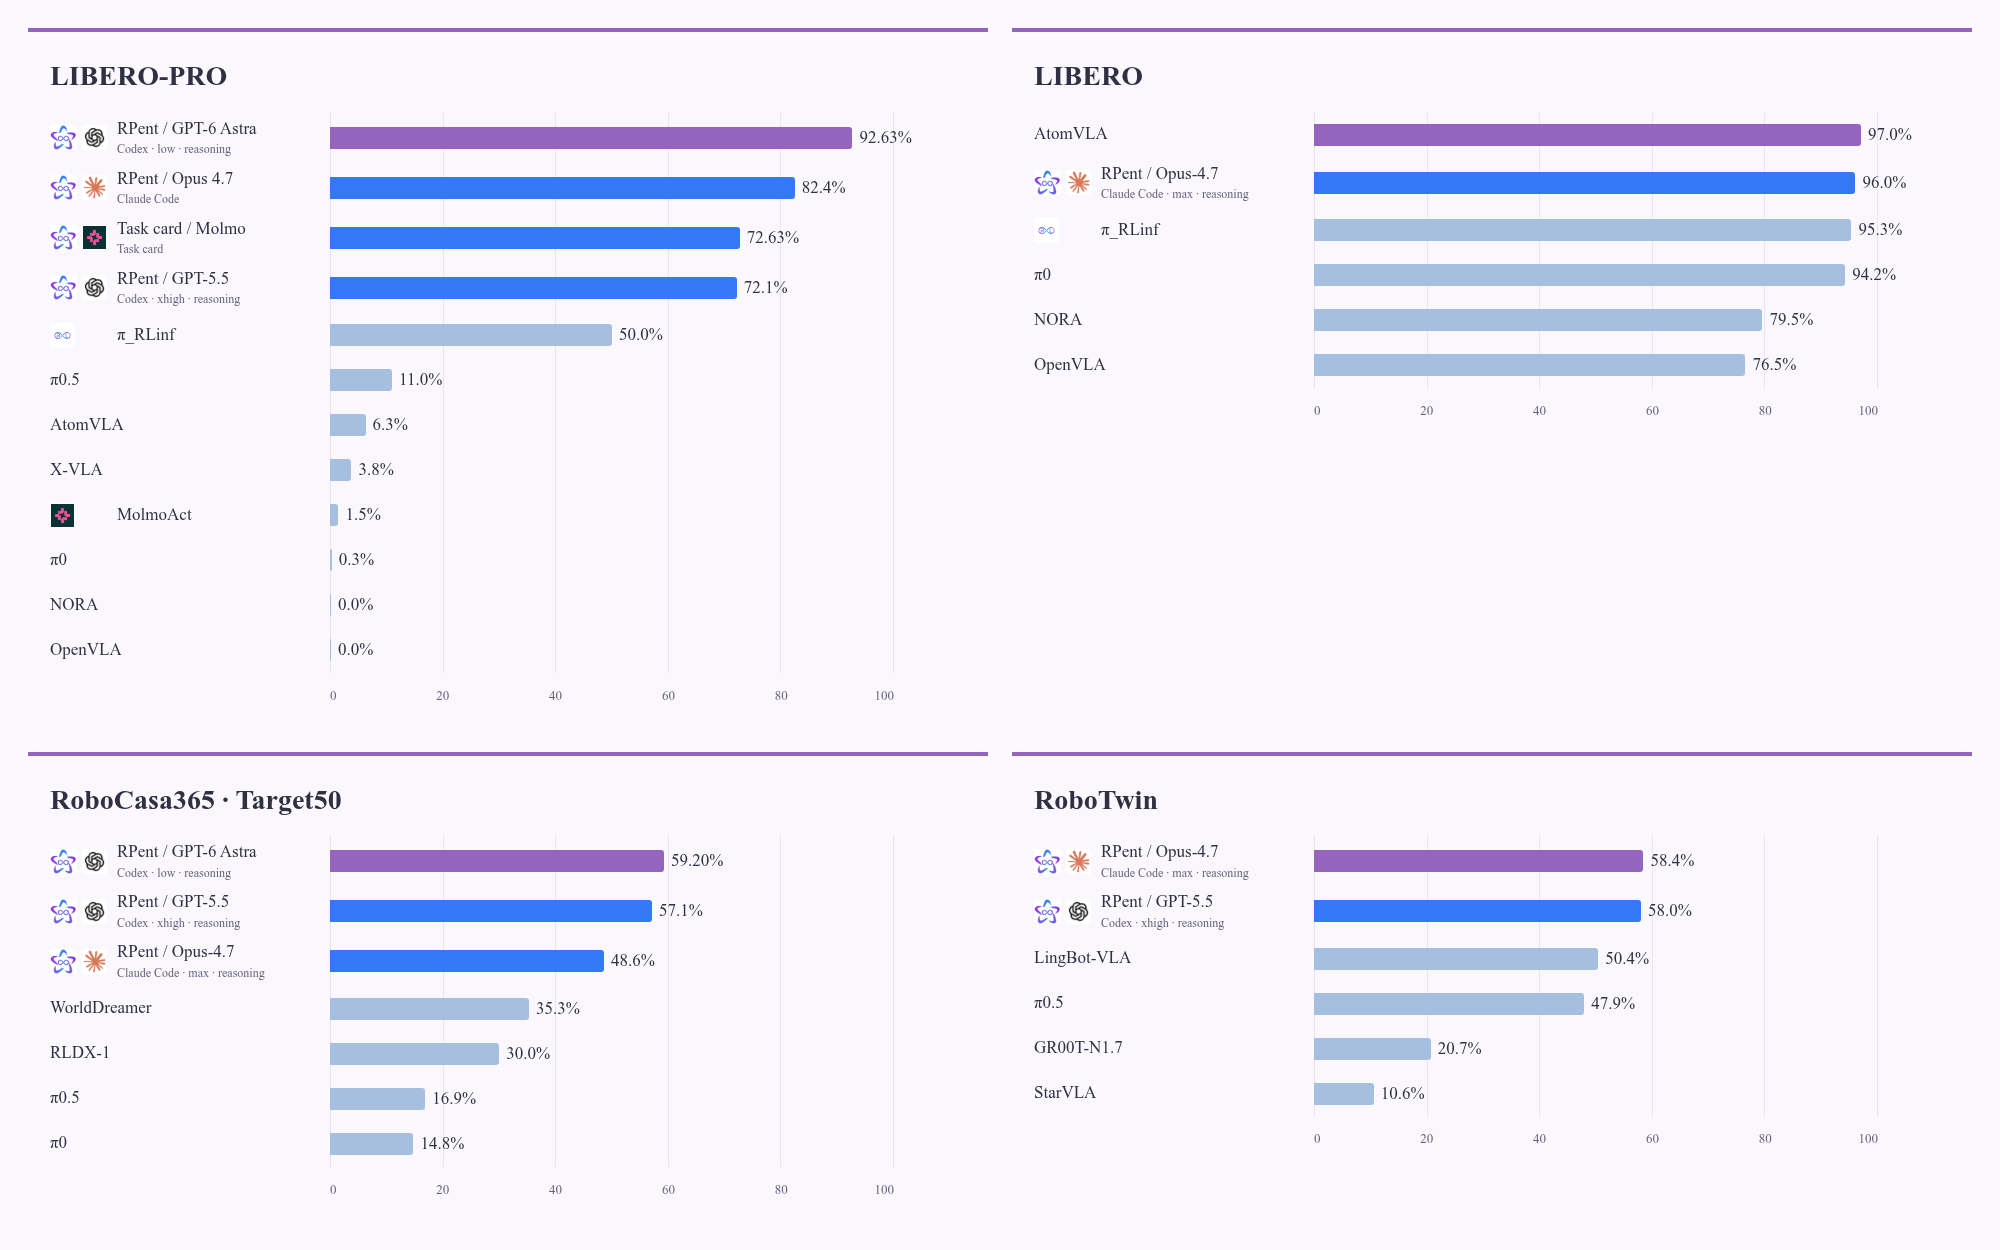](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html)
## Who Should Consider Using RPent?
diff --git a/README.zh-CN.md b/README.zh-CN.md
index 952ab19e4..267e98818 100644
--- a/README.zh-CN.md
+++ b/README.zh-CN.md
@@ -33,7 +33,7 @@
Codex / GPT-6 Astra / low / reasoning 已完成全部八套 LIBERO-PRO,**Overall 92.63%(741/800)**。详见 [套件汇总](https://rpent.readthedocs.io/zh-cn/latest/rst_source/benchmarks.html),其中 Long 与 Spatial/Object/Goal 分别使用各自冻结的 memory 批次。
-[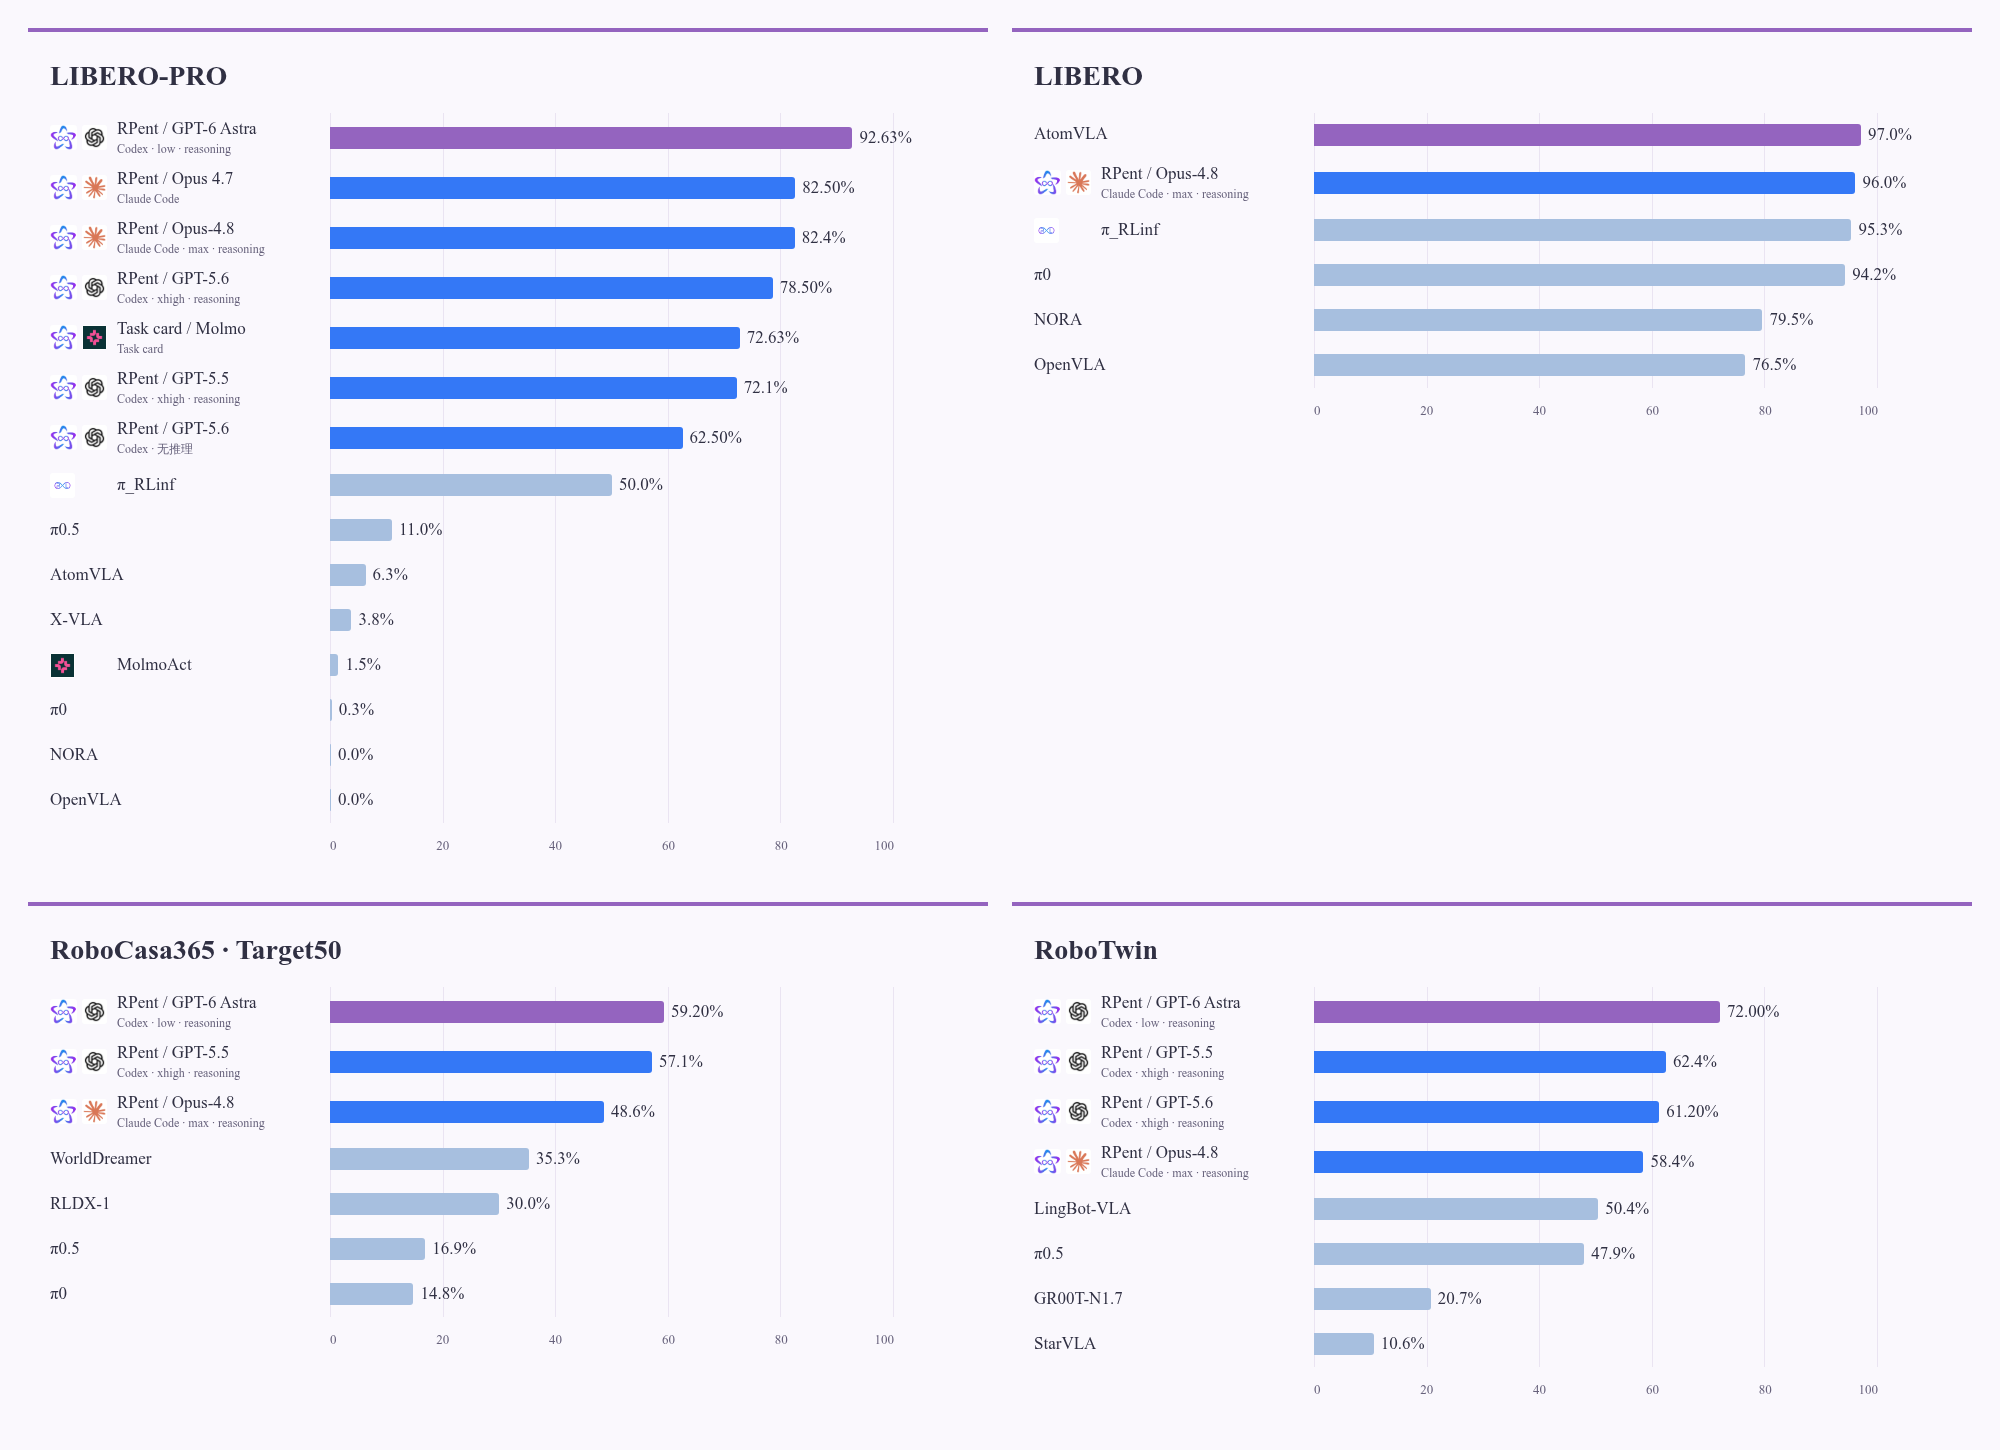](https://rpent.readthedocs.io/zh-cn/latest/rst_source/benchmarks.html)
+[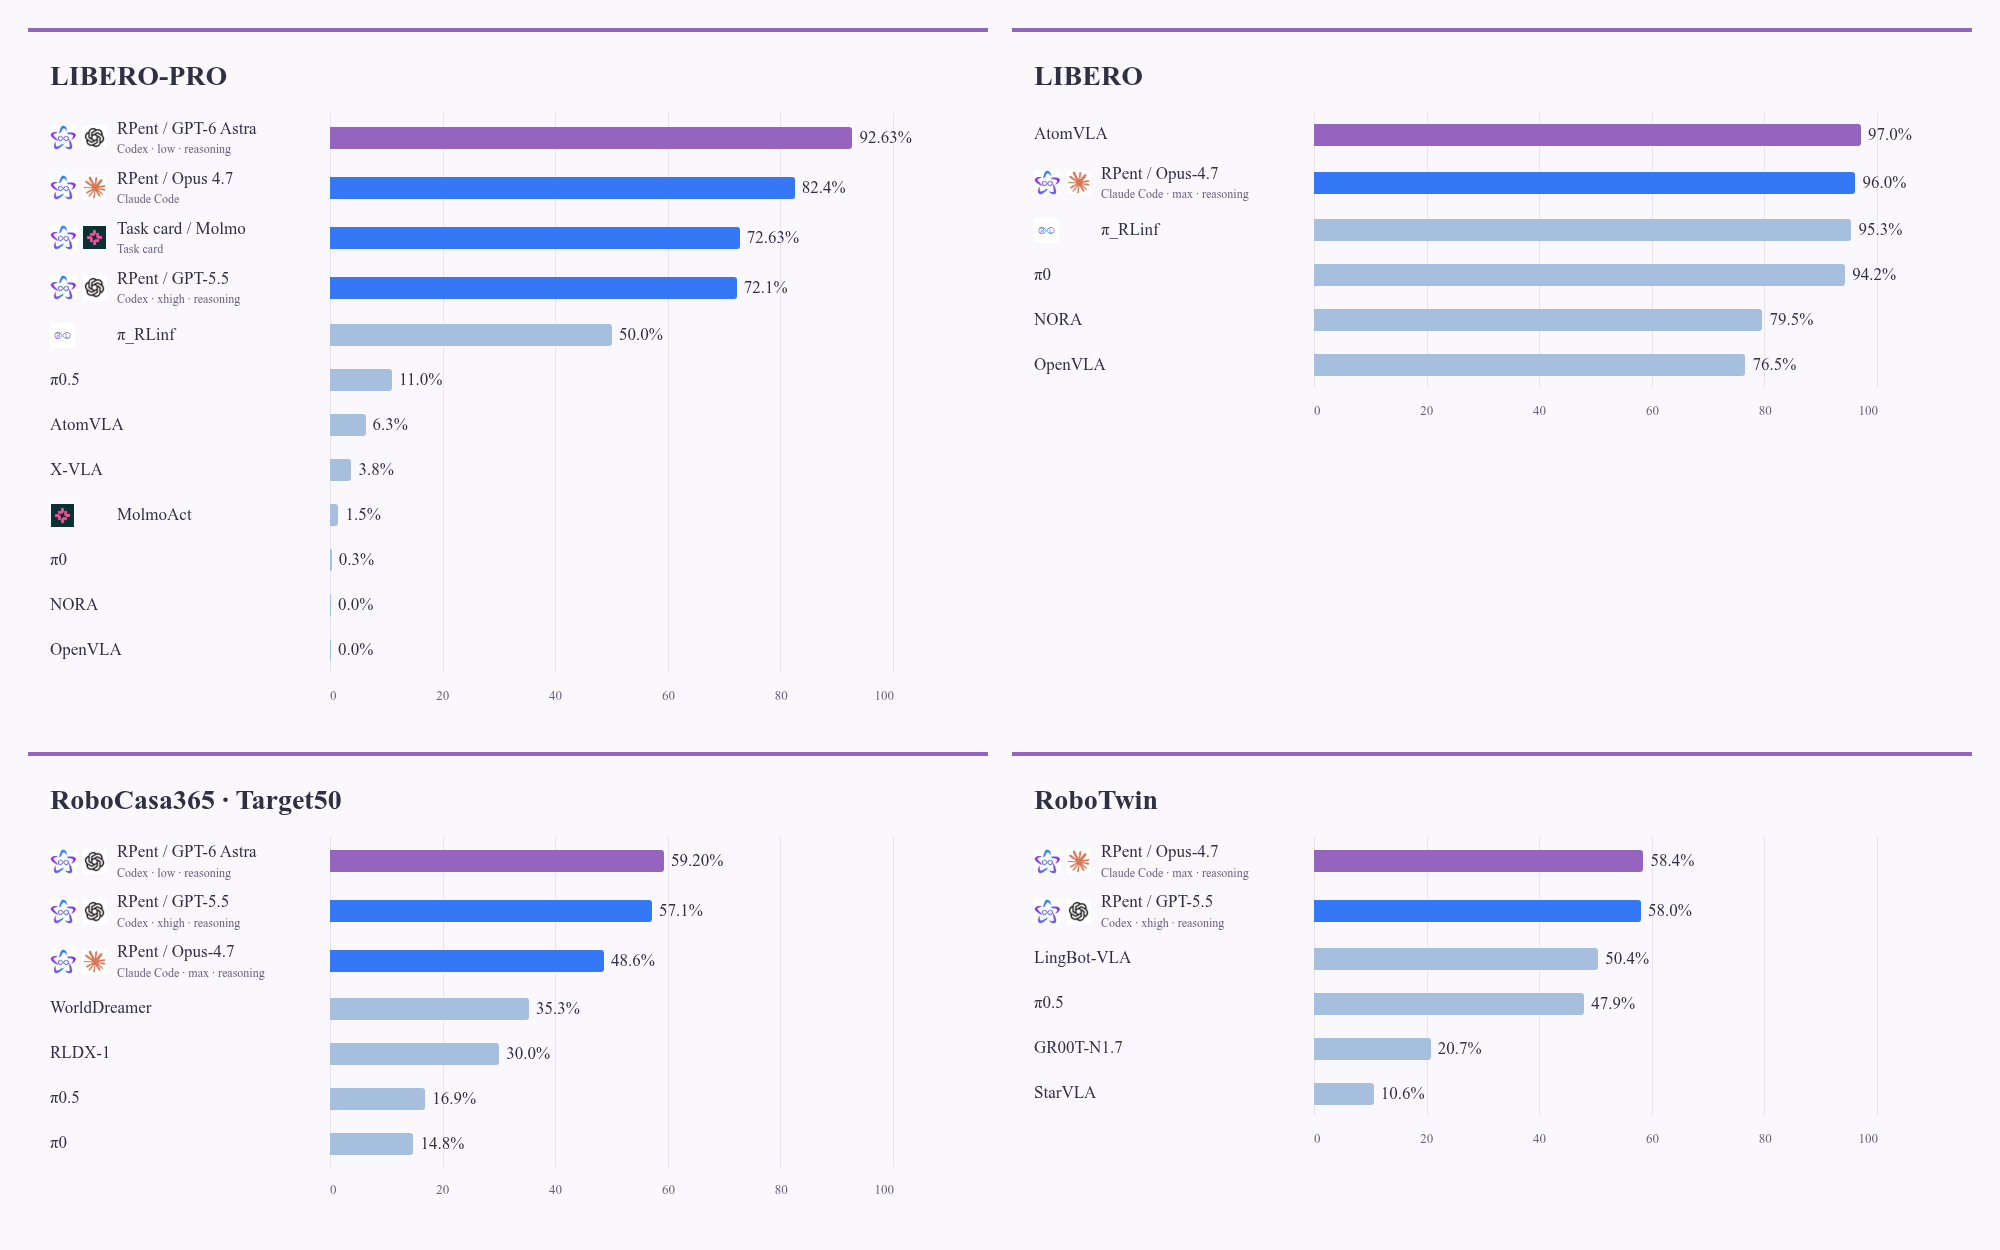](https://rpent.readthedocs.io/zh-cn/latest/rst_source/benchmarks.html)
## 适用用户
diff --git a/docs/source-en/rst_source/benchmarks.rst b/docs/source-en/rst_source/benchmarks.rst
index 7ea6b6995..f20768a1f 100644
--- a/docs/source-en/rst_source/benchmarks.rst
+++ b/docs/source-en/rst_source/benchmarks.rst
@@ -9,17 +9,17 @@ RPent Leaderboard
.. raw:: html
-
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/7551b6b0a0228e9c9fd2b70ef994b0c40f1b1412/rpent/benchmarks/results.json">
-
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.50% Claude Code / Opus-4.8 / max / reasoning 82.4% Codex / GPT-5.6 / xhigh / reasoning 78.50% Task card / Molmo 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% Codex / GPT-5.6 / no reasoning 62.50% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% OpenVLA 0.0% NORA 0.0%
-
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.8 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.8 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin Method / model Success rate Codex / GPT-6 Astra / low / reasoning 72.00% Codex / GPT-5.5 / xhigh / reasoning 62.4% Codex / GPT-5.6 / xhigh / reasoning 61.20% Claude Code / Opus-4.8 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% Task card / Molmo 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
+
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
+
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
+
RoboTwin Method / model Success rate Claude Code / Opus-4.7 / max / reasoning 58.4% Codex / GPT-5.5 / xhigh / reasoning 58.0% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra · low · reasoning: LIBERO-PRO 92.63% (741/800).
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/7551b6b0a0228e9c9fd2b70ef994b0c40f1b1412/rpent/benchmarks/results.json">
-
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.50% Claude Code / Opus-4.8 / max / reasoning 82.4% Codex / GPT-5.6 / xhigh / reasoning 78.50% Task card / Molmo 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% Codex / GPT-5.6 / 无推理 62.50% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% OpenVLA 0.0% NORA 0.0%
-
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.8 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.8 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 72.00% Codex / GPT-5.5 / xhigh / reasoning 62.4% Codex / GPT-5.6 / xhigh / reasoning 61.20% Claude Code / Opus-4.8 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% Task card / Molmo 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
+
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
+
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
+
RoboTwin 方法 / 模型 成功率 Claude Code / Opus-4.7 / max / reasoning 58.4% Codex / GPT-5.5 / xhigh / reasoning 58.0% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra · low · reasoning:LIBERO-PRO 92.63%(741/800)。
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/29a9d96588fbd9fa01cb4e035658eba028384fb6/rpent/benchmarks/results.json">
-
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% Task card / Molmo 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
+
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin Method / model Success rate Claude Code / Opus-4.7 / max / reasoning 58.4% Codex / GPT-5.5 / xhigh / reasoning 58.0% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
+
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra · low · reasoning: LIBERO-PRO 92.63% (741/800).
+
RPent Flash Mode: 72.63% (581/800). Molmo is used for visual localization only.
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/29a9d96588fbd9fa01cb4e035658eba028384fb6/rpent/benchmarks/results.json">
-
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% Task card / Molmo 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
+
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin 方法 / 模型 成功率 Claude Code / Opus-4.7 / max / reasoning 58.4% Codex / GPT-5.5 / xhigh / reasoning 58.0% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
+
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra · low · reasoning:LIBERO-PRO 92.63%(741/800)。
+
RPent Flash Mode: 72.63% (581/800). Molmo 仅用于视觉定位。
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/07c25bdb9c036ecc437f8e83c8117a080e4a6d2e/rpent/benchmarks/results.json">
-
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
+
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
-
GPT-6 Astra · low · reasoning: LIBERO-PRO 92.63% (741/800).
-
RPent Flash Mode: 72.63% (581/800). Molmo is used for visual localization only.
+
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
+
ASPIRE: six main-suite scores; Long uses zero-shot transfer from LIBERO-90. No eight-suite Overall is reported. Flash Mode uses Molmo2-8B for visual localization, not planning.
ASPIRE Suite Success rate Evaluation Object Swap 98.0% Held-out seeds 1-50 Object Task 95.0% Held-out seeds 1-50 Goal Swap 81.0% Held-out seeds 1-50 Spatial Task 60.0% Held-out seeds 1-50 Spatial Swap 51.0% Held-out seeds 1-50 Goal Task 45.0% Held-out seeds 1-50 Long Task 38.3% Long zero-shot transfer (LIBERO-90 library) Long Swap 22.6% Long zero-shot transfer (LIBERO-90 library)
RPent Flash Mode · Task + Swap totals Exact combined counts printed in the published figure; individual Task/Swap counts are not reported in text. These are not eight-suite component scores.
Suite Success rate Success / evaluated Object 89.5% 179/200 Spatial 74.5% 149/200 Goal 69.5% 139/200 Long 57.0% 114/200
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/07c25bdb9c036ecc437f8e83c8117a080e4a6d2e/rpent/benchmarks/results.json">
-
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3% NORA 0.0% OpenVLA 0.0%
+
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
-
GPT-6 Astra · low · reasoning:LIBERO-PRO 92.63%(741/800)。
-
RPent Flash Mode: 72.63% (581/800). Molmo 仅用于视觉定位。
+
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
+
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移,未报告八套件 Overall。Flash Mode 使用 Molmo2-8B 进行视觉定位,不用于规划。
ASPIRE 分项 成功率 评测 Object Swap 98.0% 保留测试 seed 1-50 Object Task 95.0% 保留测试 seed 1-50 Goal Swap 81.0% 保留测试 seed 1-50 Spatial Task 60.0% 保留测试 seed 1-50 Spatial Swap 51.0% 保留测试 seed 1-50 Goal Task 45.0% 保留测试 seed 1-50 Long Task 38.3% Long 零样本迁移(LIBERO-90 技能库) Long Swap 22.6% Long 零样本迁移(LIBERO-90 技能库)
RPent Flash Mode · Task + Swap 汇总 采用公开图中明确标注的合计次数;未按柱高估算各 Task/Swap 次数,不能将合计作为单个分项。
套件 成功率 成功 / 总回合 Object 89.5% 179/200 Spatial 74.5% 149/200 Goal 69.5% 139/200 Long 57.0% 114/200
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/10140de07db9c6a0a8c0e1683dc27351e0e319e2/rpent/benchmarks/results.json">
-
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
+
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE: six main-suite scores; Long uses zero-shot transfer from LIBERO-90. No eight-suite Overall is reported. Flash Mode uses Molmo2-8B for visual localization, not planning.
ASPIRE Suite Success rate Evaluation Object Swap 98.0% Held-out seeds 1-50 Object Task 95.0% Held-out seeds 1-50 Goal Swap 81.0% Held-out seeds 1-50 Spatial Task 60.0% Held-out seeds 1-50 Spatial Swap 51.0% Held-out seeds 1-50 Goal Task 45.0% Held-out seeds 1-50 Long Task 38.3% Long zero-shot transfer (LIBERO-90 library) Long Swap 22.6% Long zero-shot transfer (LIBERO-90 library)
RPent Flash Mode · Task + Swap totals Exact combined counts printed in the published figure; individual Task/Swap counts are not reported in text. These are not eight-suite component scores.
Suite Success rate Success / evaluated Object 89.5% 179/200 Spatial 74.5% 149/200 Goal 69.5% 139/200 Long 57.0% 114/200
+
ASPIRE: six main-suite evaluations; Long is zero-shot transfer from the LIBERO-90 skill library.
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% — — — — — — — — GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE (eight-score arithmetic mean) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/10140de07db9c6a0a8c0e1683dc27351e0e319e2/rpent/benchmarks/results.json">
-
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
+
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移,未报告八套件 Overall。Flash Mode 使用 Molmo2-8B 进行视觉定位,不用于规划。
ASPIRE 分项 成功率 评测 Object Swap 98.0% 保留测试 seed 1-50 Object Task 95.0% 保留测试 seed 1-50 Goal Swap 81.0% 保留测试 seed 1-50 Spatial Task 60.0% 保留测试 seed 1-50 Spatial Swap 51.0% 保留测试 seed 1-50 Goal Task 45.0% 保留测试 seed 1-50 Long Task 38.3% Long 零样本迁移(LIBERO-90 技能库) Long Swap 22.6% Long 零样本迁移(LIBERO-90 技能库)
RPent Flash Mode · Task + Swap 汇总 采用公开图中明确标注的合计次数;未按柱高估算各 Task/Swap 次数,不能将合计作为单个分项。
套件 成功率 成功 / 总回合 Object 89.5% 179/200 Spatial 74.5% 149/200 Goal 69.5% 139/200 Long 57.0% 114/200
+
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移。
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% — — — — — — — — GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE(八项算术平均) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/b69d555969600e853d8071eb19112502583b1e06/rpent/benchmarks/results.json">
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE: six main-suite evaluations; Long is zero-shot transfer from the LIBERO-90 skill library.
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% — — — — — — — — GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE (eight-score arithmetic mean) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+
ASPIRE: six main-suite evaluations; Long is zero-shot transfer from the LIBERO-90 skill library.
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE (eight-score arithmetic mean) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/b69d555969600e853d8071eb19112502583b1e06/rpent/benchmarks/results.json">
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移。
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% — — — — — — — — GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE(八项算术平均) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移。
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE(八项算术平均) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/36f26c2d0cdb2e00b78b6ea3166e4c265c45b51f/rpent/benchmarks/results.json">
-
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
-
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
+
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
+
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
+
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE: six main-suite evaluations; Long is zero-shot transfer from the LIBERO-90 skill library.
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE (eight-score arithmetic mean) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+
ASPIRE: six main-suite evaluations; Long is zero-shot transfer from the LIBERO-90 skill library.
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE (eight-score arithmetic mean) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/36f26c2d0cdb2e00b78b6ea3166e4c265c45b51f/rpent/benchmarks/results.json">
-
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus 4.7 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
-
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max / reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max / reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max / reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
+
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
+
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
+
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移。
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus 4.7 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE(八项算术平均) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移。
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE(八项算术平均) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/fbb158d608554595dcd2d4aae6fcc42e8f71c86b/rpent/benchmarks/results.json">
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE: six main-suite evaluations; Long is zero-shot transfer from the LIBERO-90 skill library.
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE (eight-score arithmetic mean) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/fbb158d608554595dcd2d4aae6fcc42e8f71c86b/rpent/benchmarks/results.json">
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
ASPIRE:六项常规评测;Long 为 LIBERO-90 技能库零样本迁移。
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE(八项算术平均) 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
+
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/15da23a9cbc402c92cd6ea05a4f71adedcaf6a99/rpent/benchmarks/results.json">
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
@@ -22,5 +22,6 @@ RPent Leaderboard
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
+
RoboCasa365 · Target50 · All methods & reported scores Method / model Overall Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
GPT-6 Astra: seeds 1–5 for each of the 50 tasks, 250 episodes in total.
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/15da23a9cbc402c92cd6ea05a4f71adedcaf6a99/rpent/benchmarks/results.json">
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
@@ -22,5 +22,6 @@ RPent 排行榜
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
+
RoboCasa365 · Target50 · 完整方法与分项成绩 方法 / 模型 总体 Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
GPT-6 Astra:50 个任务各使用 seed 1–5,共 250 回合。
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/f3ddb1a933f631cc5c9650cd8d345c56bfc32648/rpent/benchmarks/results.json">
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
@@ -22,6 +22,6 @@ RPent Leaderboard
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
-
RoboCasa365 · Target50 · All methods & reported scores Method / model Overall Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
GPT-6 Astra: seeds 1–5 for each of the 50 tasks, 250 episodes in total.
+
RoboCasa365 · Target50 · All methods & reported scores Method / model Overall Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
+ data-results-url="https://raw.githubusercontent.com/RLinf/misc/f3ddb1a933f631cc5c9650cd8d345c56bfc32648/rpent/benchmarks/results.json">
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
@@ -22,6 +22,6 @@ RPent 排行榜
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
-
RoboCasa365 · Target50 · 完整方法与分项成绩 方法 / 模型 总体 Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
GPT-6 Astra:50 个任务各使用 seed 1–5,共 250 回合。
+
RoboCasa365 · Target50 · 完整方法与分项成绩 方法 / 模型 总体 Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
+ data-results-url="https://cdn.jsdelivr.net/gh/RLinf/misc@44420395c8a31ff5065f1ebede08ed19255b3711/rpent/benchmarks/results.json">
-
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
-
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
-
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
-
RoboCasa365 · Target50 · All methods & reported scores Method / model Overall Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
+
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
GPT-6 Astra: Long Task/Swap and the other six suites use separate memory-file snapshots frozen after their respective exploration phases, with no updates during evaluation. Overall combines two non-overlapping batches: Long 157/200 plus the other suites 584/600, giving 741/800 (92.63%); the 800 episodes do not share a single memory snapshot.
+
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
+
RoboCasa365 · Target50 Method / model Success rate Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboCasa365 · Target50 · All methods & reported scores Method / model Overall Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
+
RoboTwin Method / model Success rate Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+ data-results-url="https://cdn.jsdelivr.net/gh/RLinf/misc@44420395c8a31ff5065f1ebede08ed19255b3711/rpent/benchmarks/results.json">
-
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
-
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
-
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
-
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
-
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
-
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
-
RoboCasa365 · Target50 · 完整方法与分项成绩 方法 / 模型 总体 Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
+
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
GPT-6 Astra:Long Task/Swap 与其余六套件使用各自探索后冻结的 memory 文件快照,评测期间不更新。Overall 合并两个不重叠批次:Long 157/200,加上其余套件 584/600,得到 741/800(92.63%);并非全部回合共享同一份 memory 快照。
+
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
+
RoboCasa365 · Target50 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 59.20% Xiaomi-Robotics-1 57.4% Codex / GPT-5.5 / xhigh / reasoning 57.1% Claude Code / Opus-4.7 / max.reasoning 48.6% WorldDreamer 35.3% RLDX-1 30.0% π0.5 16.9% π0 14.8%
RoboCasa365 · Target50 · 完整方法与分项成绩 方法 / 模型 总体 Atomic-Seen Composite-Seen Composite-Unseen GPT-6 Astra 59.20% 87.78% 43.75% 42.50% Xiaomi-Robotics-1 57.4% 80.2% 57.1% 32.1% GPT-5.5 57.1% 92.0% 61.0% 13.8% Opus-4.7 / max.reasoning 48.6% 79.4% 47.5% 15.0% WorldDreamer 35.3% 66.3% 26.7% 9.0% RLDX-1 30.0% 60.0% 21.3% 5.0% π0.5 16.9% 39.6% 7.1% 1.2% π0 14.8% 34.6% 6.1% 1.1%
+
RoboTwin 方法 / 模型 成功率 Codex / GPT-5.5 / xhigh / reasoning 62.4% Claude Code / Opus-4.7 / max.reasoning 58.4% LingBot-VLA 50.4% π0.5 47.9% GR00T-N1.7 20.7% StarVLA 10.6%
+ data-results-url="https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/results.json">
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
GPT-6 Astra: Long Task/Swap and the other six suites use separate memory-file snapshots frozen after their respective exploration phases, with no updates during evaluation. Overall combines two non-overlapping batches: Long 157/200 plus the other suites 584/600, giving 741/800 (92.63%); the 800 episodes do not share a single memory snapshot.
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
diff --git a/docs/source-en/rst_source/overview.rst b/docs/source-en/rst_source/overview.rst
index 34f9cefb7..2c98d0a02 100644
--- a/docs/source-en/rst_source/overview.rst
+++ b/docs/source-en/rst_source/overview.rst
@@ -33,13 +33,13 @@ Compare success rates on LIBERO, LIBERO-PRO, RoboCasa365 Target50, and RoboTwin
C2R. Rankings apply to the methods and evaluation coverage shown; see
:doc:`benchmarks` for detailed results, configurations, and sources.
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@44420395c8a31ff5065f1ebede08ed19255b3711/rpent/benchmarks/leaderboard-en-light.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-en-light.png
:alt: RPent benchmark results
:class: only-light
:width: 100%
:target: benchmarks.html
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@44420395c8a31ff5065f1ebede08ed19255b3711/rpent/benchmarks/leaderboard-en-dark.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-en-dark.png
:alt: RPent benchmark results
:class: only-dark
:width: 100%
diff --git a/docs/source-zh/rst_source/benchmarks.rst b/docs/source-zh/rst_source/benchmarks.rst
index abb88a8e8..f00bf090f 100644
--- a/docs/source-zh/rst_source/benchmarks.rst
+++ b/docs/source-zh/rst_source/benchmarks.rst
@@ -9,12 +9,12 @@ RPent 排行榜
.. raw:: html
-
-
-
-
+
+
+
+
+ data-results-url="https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/results.json">
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
GPT-6 Astra:Long Task/Swap 与其余六套件使用各自探索后冻结的 memory 文件快照,评测期间不更新。Overall 合并两个不重叠批次:Long 157/200,加上其余套件 584/600,得到 741/800(92.63%);并非全部回合共享同一份 memory 快照。
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
diff --git a/docs/source-zh/rst_source/overview.rst b/docs/source-zh/rst_source/overview.rst
index 19403e2a8..36f7188e0 100644
--- a/docs/source-zh/rst_source/overview.rst
+++ b/docs/source-zh/rst_source/overview.rst
@@ -25,13 +25,13 @@ RPent 建立在三条核心设计原则之上: **服务化、标准化、可组
对比 LIBERO、LIBERO-PRO、RoboCasa365 Target50 和 RoboTwin C2R 上的成功率。
排名仅限图中方法及评测范围;完整结果、模型配置和来源见 :doc:`benchmarks`。
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@44420395c8a31ff5065f1ebede08ed19255b3711/rpent/benchmarks/leaderboard-zh-light.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-zh-light.png
:alt: RPent benchmark results
:class: only-light
:width: 100%
:target: benchmarks.html
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@44420395c8a31ff5065f1ebede08ed19255b3711/rpent/benchmarks/leaderboard-zh-dark.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-zh-dark.png
:alt: RPent benchmark results
:class: only-dark
:width: 100%
From c8b2d89feb32ea9d09e214124ae6224629695965 Mon Sep 17 00:00:00 2001
From: ye shengjie <184427520+ye1457@users.noreply.github.com>
Date: Thu, 17 Sep 2026 06:37:42 +0000
Subject: [PATCH 13/13] docs: pin leaderboard scroll clearance for fixed
navigation
---
README.md | 2 +-
README.zh-CN.md | 2 +-
docs/source-en/rst_source/benchmarks.rst | 10 +++++-----
docs/source-en/rst_source/overview.rst | 4 ++--
docs/source-zh/rst_source/benchmarks.rst | 10 +++++-----
docs/source-zh/rst_source/overview.rst | 4 ++--
6 files changed, 16 insertions(+), 16 deletions(-)
diff --git a/README.md b/README.md
index c83c52874..80a9ea9bf 100644
--- a/README.md
+++ b/README.md
@@ -33,7 +33,7 @@ Compare RPent with reference methods on LIBERO, LIBERO-PRO, RoboCasa365 Target50
Codex / GPT-6 Astra / low / reasoning: **92.63% Overall (741/800)** across all eight LIBERO-PRO suites. See the [suite results and memory-batch explanation](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html#libero-pro-astra-memory), including the separately frozen Long and Spatial/Object/Goal memory batches.
-[](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html)
+[](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html)
## Who Should Consider Using RPent?
diff --git a/README.zh-CN.md b/README.zh-CN.md
index ea73d34a0..800b6f524 100644
--- a/README.zh-CN.md
+++ b/README.zh-CN.md
@@ -33,7 +33,7 @@
Codex / GPT-6 Astra / low / reasoning 已完成全部八套 LIBERO-PRO,**Overall 92.63%(741/800)**。详见 [套件汇总与 memory 批次说明](https://rpent.readthedocs.io/zh-cn/latest/rst_source/benchmarks.html#libero-pro-astra-memory),其中 Long 与 Spatial/Object/Goal 分别使用各自冻结的 memory 批次。
-[](https://rpent.readthedocs.io/zh-cn/latest/rst_source/benchmarks.html)
+[](https://rpent.readthedocs.io/zh-cn/latest/rst_source/benchmarks.html)
## 适用用户
diff --git a/docs/source-en/rst_source/benchmarks.rst b/docs/source-en/rst_source/benchmarks.rst
index bf183dcfe..c9a203b7f 100644
--- a/docs/source-en/rst_source/benchmarks.rst
+++ b/docs/source-en/rst_source/benchmarks.rst
@@ -9,12 +9,12 @@ RPent Leaderboard
.. raw:: html
-
-
-
-
+
+
+
+
+ data-results-url="https://cdn.jsdelivr.net/gh/RLinf/misc@c3b9b5d4ffa360a8324c5b7aa510e1ed0876aa43/rpent/benchmarks/results.json">
LIBERO-PRO Method / model Success rate Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
All methods & reported scores Method / model Overall Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE: Long Task and Long Swap use zero-shot transfer from the LIBERO-90 skill library.
GPT-6 Astra: Long Task/Swap and the other six suites use separate memory-file snapshots frozen after their respective exploration phases, with no updates during evaluation. Overall combines two non-overlapping batches: Long 157/200 plus the other suites 584/600, giving 741/800 (92.63%); the 800 episodes do not share a single memory snapshot.
LIBERO Method / model Success rate AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
diff --git a/docs/source-en/rst_source/overview.rst b/docs/source-en/rst_source/overview.rst
index 2c98d0a02..1a8124fc6 100644
--- a/docs/source-en/rst_source/overview.rst
+++ b/docs/source-en/rst_source/overview.rst
@@ -33,13 +33,13 @@ Compare success rates on LIBERO, LIBERO-PRO, RoboCasa365 Target50, and RoboTwin
C2R. Rankings apply to the methods and evaluation coverage shown; see
:doc:`benchmarks` for detailed results, configurations, and sources.
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-en-light.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@c3b9b5d4ffa360a8324c5b7aa510e1ed0876aa43/rpent/benchmarks/leaderboard-en-light.png
:alt: RPent benchmark results
:class: only-light
:width: 100%
:target: benchmarks.html
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-en-dark.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@c3b9b5d4ffa360a8324c5b7aa510e1ed0876aa43/rpent/benchmarks/leaderboard-en-dark.png
:alt: RPent benchmark results
:class: only-dark
:width: 100%
diff --git a/docs/source-zh/rst_source/benchmarks.rst b/docs/source-zh/rst_source/benchmarks.rst
index f00bf090f..336ac3e1c 100644
--- a/docs/source-zh/rst_source/benchmarks.rst
+++ b/docs/source-zh/rst_source/benchmarks.rst
@@ -9,12 +9,12 @@ RPent 排行榜
.. raw:: html
-
-
-
-
+
+
+
+
+ data-results-url="https://cdn.jsdelivr.net/gh/RLinf/misc@c3b9b5d4ffa360a8324c5b7aa510e1ed0876aa43/rpent/benchmarks/results.json">
LIBERO-PRO 方法 / 模型 成功率 Codex / GPT-6 Astra / low / reasoning 92.63% Claude Code / Opus-4.7 / max.reasoning 82.4% RPent Flash Mode 72.63% Codex / GPT-5.5 / xhigh / reasoning 72.1% ASPIRE 61.36% π_RLinf 50.0% π0.5 11.0% AtomVLA 6.3% X-VLA 3.8% MolmoAct 1.5% π0 0.3%
GPT-6 Astra: 92.63% (741/800). RPent Flash Mode / Molmo2-8B: 72.63% (581/800).
完整方法与分项成绩 方法 / 模型 总体 Spatial Task Spatial Swap Object Task Object Swap Goal Task Goal Swap Long Task Long Swap GPT-6 Astra 92.63% 100% 98% 100% 99% 88% 99% 85% 72% Opus-4.7 / max.reasoning 82.4% — — — — — — — — RPent Flash Mode / Molmo2-8B 72.63% 79.00% 70.00% 86.00% 93.00% 74.00% 65.00% 60.00% 54.00% GPT-5.5 72.1% 81.0% 69.0% 94.0% 91.0% 75.0% 66.0% 52.0% 49.0% ASPIRE 61.36% 60.0% 51.0% 95.0% 98.0% 45.0% 81.0% 38.3% 22.6% π_RLinf 50.0% 42.0% 59.0% 71.0% 78.0% 45.0% 42.0% 49.0% 14.0% π0.5 11.0% 1.0% 20.0% 1.0% 17.0% 2.0% 38.0% 1.0% 8.0% AtomVLA 6.3% 1.0% 16.0% 0.0% 10.0% 11.0% 2.0% 9.0% 1.0% X-VLA 3.8% 0.0% 0.0% 8.0% 2.0% 9.0% 1.0% 10.0% 0.0% MolmoAct 1.5% 0.0% 0.0% 0.0% 6.0% 0.0% 0.0% 6.0% 0.0% π0 0.3% 0.0% 0.0% 0.0% 2.0% 0.0% 0.0% 0.0% 0.0% Cap-X — 14.0% 12.0% 18.0% 22.0% 17.0% 26.0% — — RATS — 31.0% 29.0% 63.0% 61.0% 36.0% 43.0% — —
ASPIRE:Long Task 和 Long Swap 使用 LIBERO-90 技能库进行 zero-shot 迁移。
GPT-6 Astra:Long Task/Swap 与其余六套件使用各自探索后冻结的 memory 文件快照,评测期间不更新。Overall 合并两个不重叠批次:Long 157/200,加上其余套件 584/600,得到 741/800(92.63%);并非全部回合共享同一份 memory 快照。
LIBERO 方法 / 模型 成功率 AtomVLA 97.0% Claude Code / Opus-4.7 / max.reasoning 96.0% π_RLinf 95.3% π0 94.2% NORA 79.5% OpenVLA 76.5%
diff --git a/docs/source-zh/rst_source/overview.rst b/docs/source-zh/rst_source/overview.rst
index 36f7188e0..af8c0749d 100644
--- a/docs/source-zh/rst_source/overview.rst
+++ b/docs/source-zh/rst_source/overview.rst
@@ -25,13 +25,13 @@ RPent 建立在三条核心设计原则之上: **服务化、标准化、可组
对比 LIBERO、LIBERO-PRO、RoboCasa365 Target50 和 RoboTwin C2R 上的成功率。
排名仅限图中方法及评测范围;完整结果、模型配置和来源见 :doc:`benchmarks`。
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-zh-light.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@c3b9b5d4ffa360a8324c5b7aa510e1ed0876aa43/rpent/benchmarks/leaderboard-zh-light.png
:alt: RPent benchmark results
:class: only-light
:width: 100%
:target: benchmarks.html
-.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@881ca8850640e1ac5e728865926349e4660032e7/rpent/benchmarks/leaderboard-zh-dark.png
+.. image:: https://cdn.jsdelivr.net/gh/RLinf/misc@c3b9b5d4ffa360a8324c5b7aa510e1ed0876aa43/rpent/benchmarks/leaderboard-zh-dark.png
:alt: RPent benchmark results
:class: only-dark
:width: 100%
 +## Benchmark Results
+
+Compare RPent with reference methods on LIBERO, LIBERO-PRO, RoboCasa365 Target50, and RoboTwin C2R. Rankings apply to the methods and evaluation coverage shown; see [Benchmark Results](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html) for suite results and model configurations.
+
+Codex / GPT-6 Astra / low / reasoning: **92.63% Overall (741/800)** across all eight LIBERO-PRO suites. See the [suite results](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html), including the separately frozen Long and Spatial/Object/Goal memory batches.
+
+[](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html)
+
+
## Who Should Consider Using RPent?
RPent is built for four kinds of users:
@@ -38,6 +47,7 @@ RPent is built for four kinds of users:
## What's NEW!
+- [2026/09] Added an interactive leaderboard and consolidated benchmark results for LIBERO, LIBERO-PRO, RoboCasa365, and RoboTwin, with model comparisons and suite-level results. Explore [Benchmark Results](https://rpent.readthedocs.io/en/latest/rst_source/benchmarks.html).
- [2026/09] 🔥 RPent supports Franka single-arm and dual-arm real-robot extensions. Doc: [Franka](https://rpent.readthedocs.io/en/latest/rst_source/usage/franka.html) · [Dual Franka](https://rpent.readthedocs.io/en/latest/rst_source/usage/dual_franka.html).
- [2026/08] 🔥 RPent supports RoboCasa with RLDX-1 as manipulation model. See the [RoboCasa setup and Target50 guide](https://rpent.readthedocs.io/en/latest/rst_source/usage/robocasa.html).
- [2026/08] 🔥 RPent supports the non-reasoning mode, which reduces average execution time by ~40%.
diff --git a/README.zh-CN.md b/README.zh-CN.md
index e45334ce8..952ab19e4 100644
--- a/README.zh-CN.md
+++ b/README.zh-CN.md
@@ -27,6 +27,15 @@