
Architectural Proof-of-Concept for Async Robot Orchestration
To architect a scalable, "Layer 2" middleware node capable of bridging the gap between stateless web orchestrators (Chalice/REST) and stateful, non-deterministic physical hardware (Fanuc, MiR, PLCs).
This project simulates a "Universal Driver" pattern:
- The Orchestrator (Client): Represents the FactoryOS control plane.
- The Robot (Server): Represents a hardware interface with variable latency.
- The Protocol: ROS 2 Actions (DDS) for robust, pre-emptible communication.
In brownfield manufacturing, latency is a feature, not a bug. A Service call blocks the thread, which is dangerous when a palletizer takes 45 seconds to complete a cycle.
- Async Pattern: Used
ActionClientto allow the Orchestrator to monitor multiple robots simultaneously without blocking. - Observability: Implemented 1Hz Feedback loops (
progress_percentage) to ensure the "FactoryOS" is never blind to the robot's state.
The "Happy Path" is easy. This architecture prioritizes the "Un-Happy Path."
- Cancellation Support: The robot node listens for
CancelGoalrequests during its execution loop. - Latency Check: Cancellation signals propagate and arrest motion in <10ms (verified in logs).
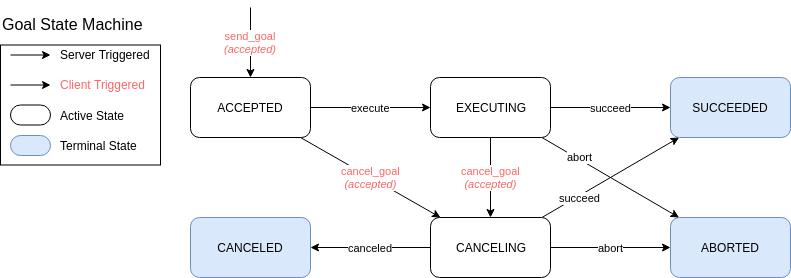
- State Integrity: Distinguishes between
ABORTED(System Failure) andCANCELED(Operator Intervention) for accurate fleet analytics.
To eliminate dependency hell and match Conduit's on-prem deployment model:
- Docker-Native: The entire stack runs in an isolated container based on
ros:jazzy. - Reproducibility: No host-side ROS installation required.
- Microservices: Nodes run as isolated processes (verified via PID checks), launched via a single entry point (
factory.launch.py). - Startup Sequence: Implemented
TimerActionlogic to enforce deterministic startup: the Action Server (factory_robot) initializes fully before the Orchestrator Client attempts connection.
1. Build the Microservice
docker build -t conduit_dev .2. Run the Simulation (Auto-Launch) This mounts the local source code (hot-reloading) and executes the launch file.
docker run -it --rm \
  -v $(pwd)/src:/root/conduit_ws/src \
  conduit_dev \
/bin/bash -c "colcon build && source install/setup.bash && ros2 launch conduit_agent factory.launch.py"Scenario: Successful Async Execution
[orchestrator]: Sending mission MISSION_001...
[factory_robot]: Received goal request
[factory_robot]: Feedback: 10.0%
[orchestrator]: Received feedback: Status: WORKING, Progress: 10.0%
...
[orchestrator]: Result: Success=True, Status=COMPLETED
Scenario: Emergency Cancellation (E-Stop)
[orchestrator]: Canceling mission after 3 seconds...
[factory_robot]: Received cancel request
[factory_robot]: Goal canceled
[orchestrator]: Result: Success=False, Status=CANCELED