Implementation of ROS2 control on a walker model. The walker has a IMU sensor.
In this repositort a walker model consists of five links and four revolute joints is controled using ROS2 control (veocity control)
Run this command:
ros2 launch my_robot my_robot_rviz.launch.py
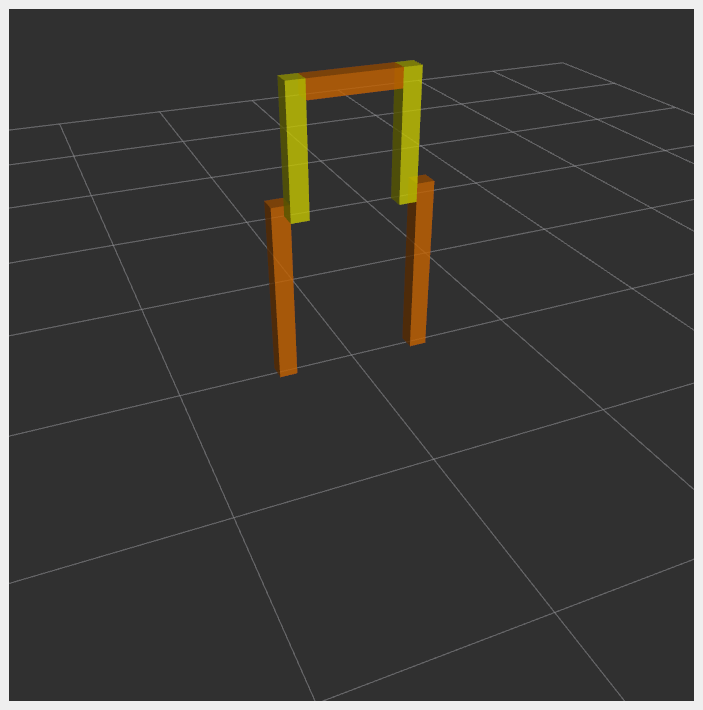
The model will show up in rviz like this:
Run this command:
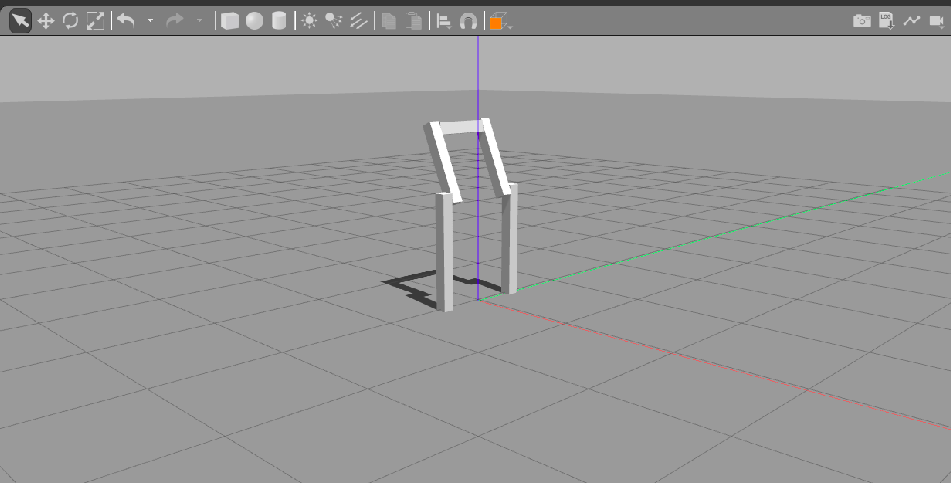
ros2 launch my_robot my_robot_nocontrol.launch.py
you can see that the walker fall down:
ros2 launch my_robot my_robot_velocity.launch.py
The robot will show up in gazebo and maintain its balance