
Shape-Aware Reinforcement Learned Model Predictive Control
Project Website · Paper · Demonstrations
Ruihua Han1, Rui Gao2, Zhe Liu1, Xinyi Wang3, Chang Chen1, Shuai Wang4, Qi Hao2, Jia Pan1, and Hengshuang Zhao1
1The University of Hong Kong · 2Southern University of Science and Technology · 3University of Michigan · 4Shenzhen Institutes of Advanced Technology
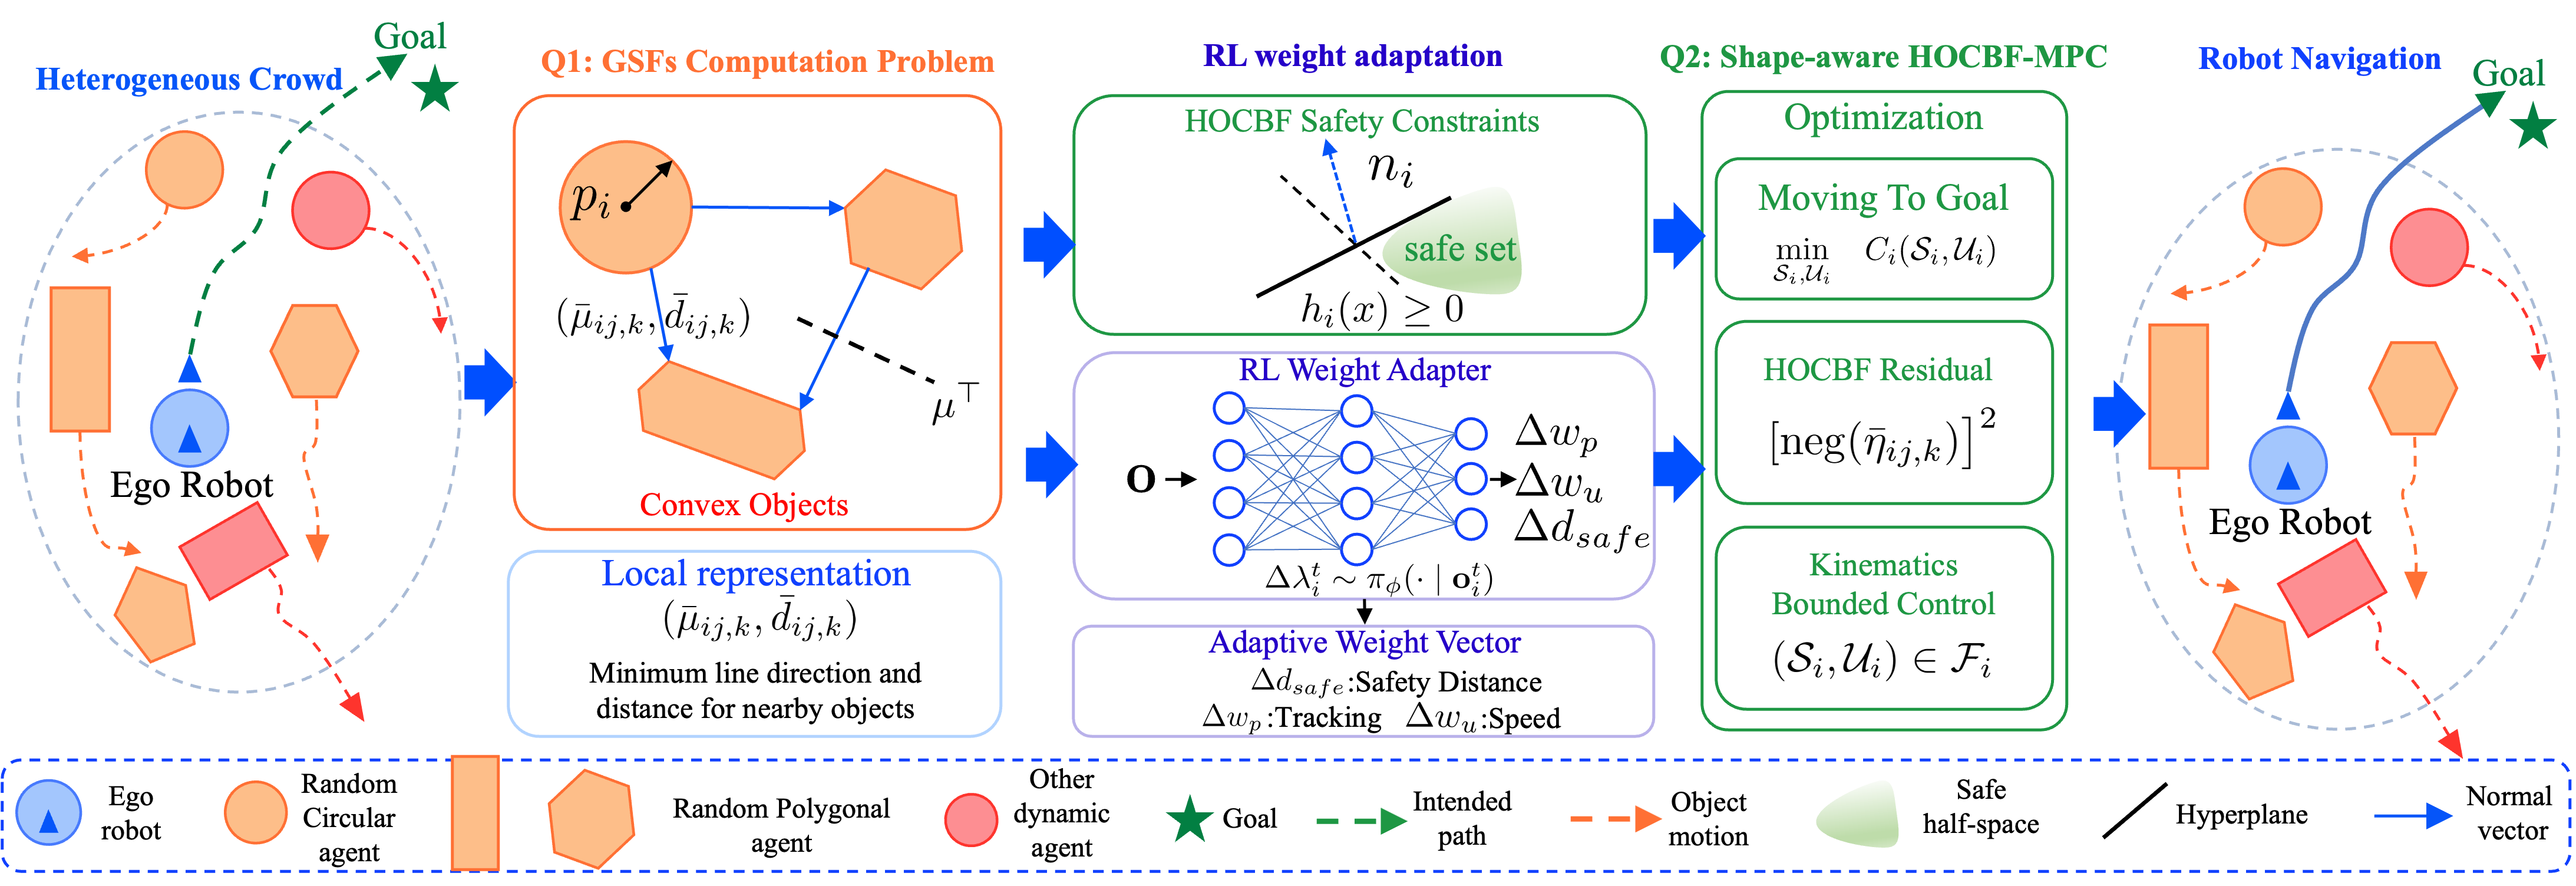
TL;DR: SRL-MPC combines shape-aware high-order control barrier functions (HOCBFs) with reinforcement learning for online MPC parameter adaptation, enabling safe and efficient navigation of heterogeneous robot shapes in dense crowds without geometry simplification or policy retraining.
- Our paper has been accepted to NeurIPS 2026!
SRL-MPC is a distributed navigation framework for heterogeneous robot crowds. It derives compact geometric separation features (GSFs) from circular and convex-polygon footprints, then uses a learned policy to adapt interpretable planning parameters from the local crowd geometry. This combines the adaptability of reinforcement learning with explicit, model-based MPC control.
The GIF previews play directly in the README; click one to open the full MP4. The simulation clips are held-out randomized episodes shown at 2× speed. The full collection is available in the demo gallery.
| Dense crowd: 25 robots | OOD: nonconvex unions | Real-world comparison |
|---|---|---|
 |
 |
 |
The source code will be released upon acceptance of the paper.