
Autodocking package repository for OpenAMRobot.
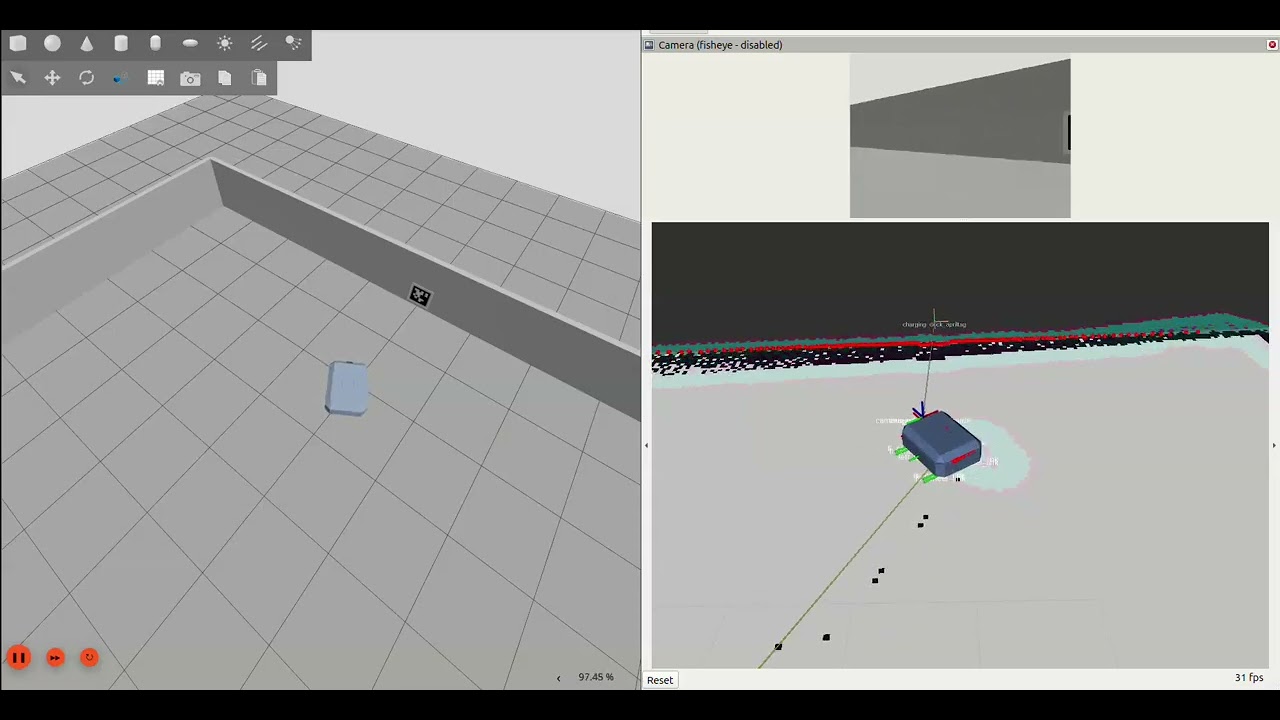
This repository contains the ROS2 docking package and its supporting documentation. Its current priority is not feature expansion, but refinement of the existing docking pipeline so it becomes clearer, more consistent, and easier to reproduce and maintain.
openamrobot_docking/- main ROS2 package
- naming consistency
- documentation quality
- package clarity
- release readiness
openamrobot_docking/README.mdopenamrobot_docking/docs/README.md
This repository supports reproducible ROS2 development using GitHub Codespaces and VS Code Dev Containers.
The development container provides a standardized ROS2 Jazzy environment for working with the OpenAMRobot docking package.
It includes:
- ROS2 Jazzy
- colcon build tools
- rosdep
- vcstool
- Python tooling
- VS Code ROS extension support
This helps contributors, interns, and students start working with the package without manually installing ROS2 on their local machine.
-
Open the repository on GitHub.
-
Click
Code. -
Select
Codespaces. -
Click
Create codespace on main. -
Wait until the container is built.
-
Open a terminal and verify the environment:
echo $ROS_DISTRO colcon --help
Expected ROS distribution:
jazzy
Build the package:
colcon build
The same .devcontainer/ configuration can be used on a local machine.
Requirements:
- Docker
- Visual Studio Code
- VS Code Dev Containers extension
Steps:
-
Clone the repository:
git clone https://github.com/openAMRobot/openamrobot-docking.git cd openamrobot-docking
-
Open the folder in VS Code.
-
Run:
Dev Containers: Reopen in Container
-
Wait until the container is built.
-
Verify ROS2:
echo $ROS_DISTRO colcon --help
The current devcontainer is intentionally lightweight and focused on docking-package development.
It is intended for:
- building the package
- editing ROS2 source code
- testing launch files
- onboarding contributors
- preparing future docking simulation work
Simulation-specific dependencies may be added later when the simulation structure is integrated, for example:
- Gazebo / Gazebo Harmonic
- ros_gz
- xacro
- robot_state_publisher
- joint_state_publisher
- rviz2
- Nav2, only if directly required by this repository
The full autonomy stack should be maintained in a higher-level OpenAMRobot integration repository, not directly inside this docking package.
Recommended separation:
openamrobot-docking
  lightweight docking-focused development container

openamr or future integration repository
  full autonomy stack
  Nav2
  SLAM
  Gazebo
  full robot simulation
  multi-package workspace