
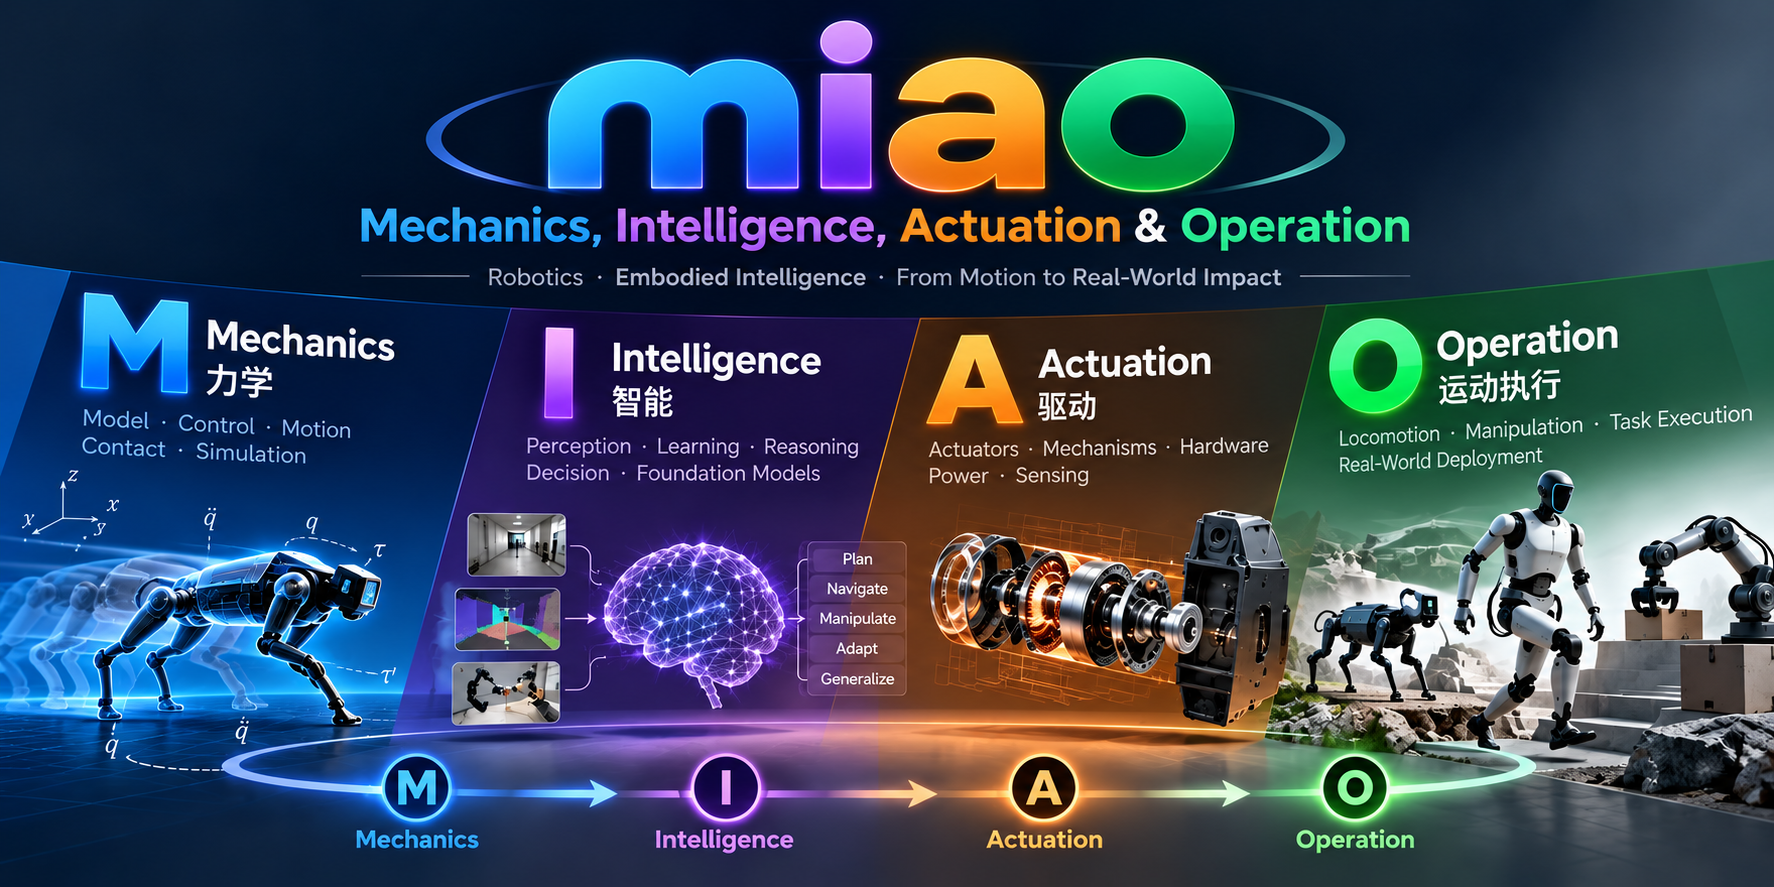
Mechanics, Intelligence, Actuation & Operation
Robotics · Embodied Intelligence · From Motion to Real-World Impact
Website / 官网 · Repositories / 代码仓库 · Open Experiment / 开放共创
miao is an open robotics community exploring embodied intelligence and learning-based control. We connect physical models, intelligent policies, robot hardware and real-world operation, bringing research closer to machines that move and act in the physical world.
miao 是一个关注机器人、具身智能与学习型控制的开放社区。我们把物理建模、策略学习、硬件驱动与运动执行连接起来,推动研究从仿真走向真实世界。
| Direction / 方向 | Focus / 关注领域 |
|---|---|
| M · Mechanics / 力学 | Modeling, control, motion, contact and simulation. 建模、控制、运动、接触与仿真。 |
| I · Intelligence / 智能 | Perception, learning, reasoning, decision-making and foundation models. 感知、学习、推理、决策与基础模型。 |
| A · Actuation / 驱动 | Actuators, mechanisms, hardware, power and sensing. 执行器、机构、硬件、动力与传感。 |
| O · Operation / 运动执行 | Locomotion, manipulation, task execution and real-world deployment. 移动、操作、任务执行与真实世界部署。 |
These directions form a closed loop: models inform policies, hardware turns commands into motion, and real-world feedback shapes the next experiment.
四个方向构成持续迭代的闭环:模型支撑策略,硬件将指令转化为运动,真实世界的反馈再推动模型与方法改进。
Projects hosted in miao-org, also featured on our website.
以下项目均托管于 miao-org 组织,也在官网展示。
| Project / 项目 | About / 简介 |
|---|---|
| RoboRadar | A local dashboard for robotics paper digests and community updates. 本地运行的机器人论文日报与社区动态工具。 |
| InfoHub | Organize chat messages into tasks, events and linked topics in a local dashboard. 在本地看板中将聊天消息整理为任务、事件与关联主题。 |
| awesome-supermimic | A curated guide to SuperMimic implementations, extensions, demos and resources. 整理 SuperMimic 实现、扩展、演示与学习资源。 |
| white-paper | A bilingual Markdown framework for a robotics engineer learning plan. 面向机器人工程师学习计划的双语 Markdown 文档框架。 |
| fill-me-with-robotics | An open community experiment shaped by robotics software contributions. 由机器人软件贡献共同塑造的开放社区实验。 |
We welcome research discussions, reproducible experiments, useful tools and contributions to open-source robotics. Share questions and results in the relevant project's Issues, or contribute code and documentation through pull requests.
欢迎围绕机器人研究交流想法、分享可复现实验、改进工具与文档。具体问题和实验结果可在对应项目的 Issues 中讨论,代码与文档贡献可通过 Pull Request 提交。
Have an idea to try? Join the open experiment: fill-me-with-robotics.
有想动手实现的点子?欢迎参与 fill-me-with-robotics 开放共创。


